Page top

CJ3M-CPU3[] / -CPU1[] / CJ2M-MD21[]

CJ-series CJ3M CPU Units, Pulse I/O Modules

CJ3M-CPU3[] / -CPU1[] / CJ2M-MD21[]

CJ Series continues. And evolves. Ideal for basic equipment upgrades and expansion

General Specifications

Item CJ3M-CPU1[]/3[]
Enclosure Mounted in a panel
Grounding Less than 100 Ω
CPU Unit Dimensions CJ3M-CPU1[]
90 mm × 75 mm × 31 mm (H × D × W)
CJ3M-CPU3[]
90 mm × 75 mm × 62 mm (H × D × W)
Weight *1 CJ3M-CPU1[]: 140 g or less
CJ3M-CPU3[]: 240 g or less
Current Consumption CJ3M-CPU1[]: 5 VDC 0.26 A, 24 VDC 0.003 A
CJ3M-CPU3[]: 5 VDC 0.91 A, 24 VDC 0.003 A
Use
Environment
Ambient Operating Temperature 0 to 55°C
Ambient Operating Humidity 10% to 90% (with no condensation)
Atmosphere Must be free from corrosive gases.
Ambient Storage Temperature -20 to 70°C
Altitude 2,000 m or less
Pollution Degree 2 or less: Conforms to IEC 61010-2-201.
Noise Immunity 2 kV on power supply line (Conforms to IEC 61000-4-4.)
Overvoltage Category Category II: Conforms to IEC 61010-2-201.
EMC Immunity Level Zone B
Vibration Resistance Conforms to IEC60068-2-6.
5 to 8.4 Hz with 3.5-mm amplitude,
8.4 to 150 Hz Acceleration of 10 m/s2 for 100 min
in X, Y, and Z directions
(10 sweeps of 10 min each = 100 min total)
Shock Resistance Conforms to IEC60068-2-27.
150 m/s2, 3 times in X, Y, and Z directions (100 m/s2
for Relay Output Units)
Battery Life 5 years at 25°C
Weight Approx. 10 g
Model CJ1W-BAT01 (Sold separately)
Applicable Standards EU, cULus, RCM, KC *2

*1. Includes the weights of the End Cover.
*2. Refer to the OMRON website (http://www.ia.omron.com/) or consult your OMRON representative for the most recent applicable standards for each model.

Performance Specifications

Items CJ3M-CPU[][]
User Memory CPU11/31: 5K steps
CPU12/32: 10K steps
CPU13/33: 20K steps
CPU14/34: 50K steps
CPU15/35: 100K steps
I/O Bits 5,120 bits
Processing
Speed
Overhead Processing Time *1 Normal Mode:CPU3[]: 260 μs
CPU1[]: 160 μs
Execution Time Basic Instructions: 0.04 μs min.;
Special Instructions: 0.06 μs min.
Interrupts I/O Interrupts and External Interrupts Interrupt task startup time: 31 μs
Return times to cyclic tasks: 10 μs
Scheduled Interrupts Minimum time interval: 0.4 ms (set in 0.1 ms increments)
Interrupt task startup time: 30 μs
Return time to cyclic task: 11 μs
Maximum Number of Connectable Units Total per CPU Rack or Expansion Rack: 10 Units max.;
Total per PLC: 80 Units max.
Basic I/O Units 80 Units max.
However, a maximum of two CJ1W-INT01 Interrupt
Input Units can be mounted.
Special I/O Units Units for up to 96 unit numbers can be mounted.
(Unit numbers run from 0 to 95. Units are allocated
between 1 and 8 unit numbers.)
CPU Bus Units CPU1[]: 16 Units max.
CPU3[]: 15 Units max.
Pulse I/O Modules 2 max.
Slots for which interrupts
can be used
Slots 0 to 4 on CPU Rack
Maximum Number of Expansion Racks 7 max.
CIO Area I/O Area 5,120 bits (320 words): Words CIO 0000 to CIO 0319
Link Area 3,200 bits (200 words): Words CIO 1000 to CIO 1199
CPU Bus Unit Area 6,400 bits (400 words): Words CIO 1500 to CIO 1899
Special I/O Unit Area 15,360 bits (960 words): Words CIO 2000 to CIO 2959
Pulse I/O Area 20 inputs, 12 outputs (CIO 2960 to CIO 2963)
Serial PLC Link Area 1,440 bits (90 words): Words CIO 3100 to CIO 3189
EtherCAT Remote Area 2,368 bits (148 words), 3,800 to 3863 words, 3,900 to
3,963 words, 3,980 to 3,999 words
DeviceNet Area 9,600 bits (600 words): Words CIO 3200 to CIO 3799
Work Area Internal I/O Area 3,200 bits (200 words):
Words CIO 1300 to CIO 1499 (Cannot be used for
external I/O.)
37,504 bits (2,344 words):
Words CIO 4000 to CIO 6143 (Cannot be used for
external I/O.)
Work Area 8,192 bits (512 words): Words W000 to W511
(Cannot be used for external I/O.)
Holding Area 8,192 bits (512 words): Words H000 to H511
Bits in this area maintain their ON/OFF status when
PLC is turned OFF or operating mode is changed.
Words H512 to H1535: These words can be used
only for function blocks. They can be used only
for function block instances (i.e., they are allocated
only for internal variables in function blocks).
Auxiliary Area Read-only: 31,744 bits (1,984 words)
• 7,168 bits (448 words): Words A0 to A447
• 24,576 bits (1,536 words): Words A10000 to A11535 *2
Read/write: 16,384 bits (1,024 words) in words
A448 to A1471 *2
Temporary Area 16 bits: TR0 to TR15
Timer Area 4,096 timer numbers (T0000 to T4095)
Counter Area 4,096 counter numbers (C0000 to C4095)
DM Area 32k words *3
• DM Area words for Special I/O Units: D20000 to D29599
(100 words × 96 Units)
• DM Area words for CPU Bus Units: D30000 to D31599
(100 words × 16 Units)
EM Area 32k words/bank × 1 to 10 banks max.: E00_00000 to
E09_32767 max. *4
CPU[]1/[]2/[]3: 1 bank
CPU[]4/[]5: 10 banks
Index Registers IR0 to IR15
These are special registers for storing PLC memory
addresses for indirect addressing.
(Index Registers can be set so that they are unique
in each task or so that they are shared by all tasks.)
Cyclic Task Flag Area 128 flags
Memory Card HMC-SD29[]: 2 GB
HMC-SD49[]: 4 GB
HMC-SD1A[]: 16 GB
Operating Modes PROGRAM Mode: Programs are not executed.
Preparations can be executed prior to program
execution in this mode.
MONITOR Mode: Programs are executed, and some
operations, such as online editing, and changes to
present values in I/O memory, are enabled in this mode.
RUN Mode: Programs are executed. This is the
normal operating mode.
Execution Mode Normal Mode
Programming Languages Ladder Logic (LD)
Sequential Function Charts (SFC)
Structured Text (ST)
Instruction Lists (IL)
Function
Blocks
Maximum number of definitions 2,048
Maximum number of instances 2,048
FB Program Area 40K steps
Tasks Type of Tasks Cyclic tasks
Interrupt tasks (Power OFF interrupt tasks, scheduled
interrupt tasks, I/O interrupt tasks, external interrupt
tasks, and input interrupt tasks (Pulse I/O Module) *3)
Number of Tasks Cyclic tasks: 128
Interrupt tasks: 256
(Interrupt tasks can be defined as cyclic tasks to
create extra cyclic tasks. Therefore, the total number
of cyclic tasks is actually 384 max.)
Symbols
(Variables)
Type of Symbols Local symbols: Can be used only within a single task
in the PLC.
Global symbols: Can be used in all tasks in the PLC.
Network symbols (tags): I/O memory in the CPU Unit
can be externally accessed using symbols, depending
on parameter settings.
Data Type of Symbols BOOL (bit)
UINT (one-word unsigned binary)
UDINT (two-word unsigned binary)
ULINT (four-word unsigned binary)
INT (one-word signed binary)
DINT (two-word signed binary)
LINT (four-word signed binary)
UINT BCD (one-word unsigned BCD) *5
UDINT BCD (two-word unsigned BCD) *5
ULINT BCD (four-word unsigned BCD) *5
REAL (two-word floating-point)
LREAL (four-word floating-point)
CHANNEL (word)
NUMBER (constant or number)
WORD (one-word hexadecimal)
DWORD (two-word hexadecimal)
LWORD (four-word hexadecimal)
STRING (1 to 255 ASCII characters)
TIMER (timer) *6
COUNTER (counter) *6
User-defined data types (data structures)
Maximum Size of Symbol 32k words
Array Symbols (Array Variables) One-dimensional arrays
Number of Array Elements 32,000 elements max.
Number of Registrable Network
Symbols (Tags)
10,000 max.
Length of Network Symbol
(Tag) Name
255 bytes max.
Encoding of Network
Symbols (Tags)
UTF-8
Data
Tracing
Memory Capacity 220,000 words
(Up to 32k words × the maximum bank number for the
CPU Unit when EM is specified in CX-Programmer)
Number of Samplings Bits = 31, one-word data = 32, two-word data = 16,
four-word data = 8
Sampling Cycle 1 to 2,550 ms (Unit: 1 ms)
Trigger Conditions • Bit
Upward/downward differentiation, ON, OFF
AND/OR condition combinations for a maximum of
4 bits
• Word
=, >, ≥, <, ≤, ≠
AND/OR condition combinations for a maximum of
2 words
• AND/OR condition combinations for bit conditions
and word conditions
File Memory Memory Card HMC-SD[][][] is used
EM file memory (Part of the EM Area can be
converted for use as file memory.)
Source/Comment Memory Program source,
comments,
program index,
and
symbol table
Capacity: 2 Mbytes
Commu-
nications
Logical
Ports for
Communications
Logical Ports 8 ports (Used for SEND, RECV, CMND, PMCR,
TXDU, and RXDU instructions.)
Extended
Logical Ports
64 ports (Used for SEND2, RECV2, CMND2, and
PMCR2 instructions.)
CIP
Communications
Specification
Class 3
(Number of
Connections)
Number of connections: 128
UCMM (Non-
connection Type)
Maximum number of clients that can communicate at
the same time: 32
Maximum number of servers that can communicate at
the same time: 32
Peripheral (USB) Port USB 2.0-compliant Type-C connector
Baud Rate 12 Mbps max.
Serial Port Interface: Conforms to EIA RS-232C.
Communications Method Half-duplex
Synchronization Method Start-stop
Baud Rate 0.3, 0.6, 1.2, 2.4, 4.8, 9.6, 19.2, 38.4, 57.6, or 115.2 (kbps)
Transmission Distance 15 m max.
EtherNet/IP Port *7 ---
Trans-
mission
Specifi-
cations
Media Access
Method
CSMA/CD
Modulation Baseband
Transmission
Paths
Star
Baud Rate 100 Mbps (100Base-TX)
Transmission
Media
Shielded twisted-pair (STP) cable; Categories: 5, 5e
Transmission
Distance
100 m (between Ethernet switch and node)
Number of
Cascade
Connections
No restrictions if Ethernet switch is used.
Commu-
nications
Specifi-
cations
CIP
Communications:
Tag Data Links
---
Number of
Connections
256
Packet Interval
(Refresh period)
0.5 to 10,000 ms (Unit: 0.5 ms)
Can be set for each connection. (Data will be
refreshed at the set interval, regardless of the
number of nodes.)
Permissible
Communications
Band *8
12,000 packets per second
Number of
Registrable Tags
256
Type of Tags CIO, DM, EM, HR, WR, and network symbols
Number of Tags
per Connection
8 (Seven tags if PLC status is included in the segment.)
Maximum Link
Data Size per
Node
184,832 words
Maximum Data
Size per
Connection
252 or 722 words *9
(Data is synchronized within each connection.)
Number of
Registrable
Tag Set
256 (1 connection = 1 segment)
Maximum Tag
Set Size
722 words (One word is used when PLC status is
included in the segment.)
Maximum
Number of Tags
Refreshable in
a Single Cycle
of CPU Unit *10
Output/send (CPU Unit to EtherNet/IP): 256
Input/receive (EtherNet/IP to CPU Unit): 256
Data Size
Refreshable
in a Single
Cycle of CPU
Unit *10
Output/send (CPU to EtherNet/IP): 6,432 words
Input/receive (EtherNet/IP to CPU): 6,432 words
Change of Tag
Data Link
Parameter
Settings during
Operation
Supported *11
Multi-cast
Packet Filter
*12
Supported
Quick Connect Originator only is supported
CIP
Communications:
Explicit Messages
---
Class 3
(Number of
Connections)
Number of connections: 128
UCMM (Non-
connection
Type)
Maximum number of clients that can communicate at
the same time: 32
Maximum number of servers that can communicate at
the same time: 32
CIP Routing Supported
(CIP routing is enabled for the following remote Units:
CJ1W-EIP21/EIP21S, CJ3M-CPU3[], CJ2H-CPU6[]-
EIP, CJ2M-CPU3[], and CS1W-EIP21/EIP21S.)
FINS Communications ---
FINS/UDP Supported
FINS/TCP 16 connections max.
Socket Service (TCP) 8 sockets max.
Socket Service (UDP) 8 sockets max.
Modbus TCP Server 8 connections max.
Modbus UDP Server Supported
Modbus TCP Client Possible by function block using Socket Service 8
connections max.
Modbus UDP Client Possible by function block using Socket Service 8
connections max.
EtherNet/IP
Conformance
Test
Conforms to CT21.
EtherNet/IP
Interface
10Base-T/100Base-TX
Auto Negotiation/Fixed Setting
Pulse I/O
(When
using Pulse
I/O Module)
External interface CJ2M-MD211 or CJ2M-MD212 Pulse I/O Module with
40-pin MIL connector
Pulse Inputs Can be used as normal inputs, interrupt inputs, quick-
response inputs, or high-speed counter inputs.
(Functions of each input must be selected in the PLC
Setup.)
Input method: Line-driver input or 24-VDC input
(selected by wiring)
Normal inputs 20 max. (10 per Pulse I/O Module)
Input constants: Set in the PLC Setup (0, 0.5, 1, 2, 4,
8, 16, or 32 ms). Default: 8 ms
Interrupt inputs
and quick-response inputs
8 max. (4 per Pulse I/O Module)
Input signal minimum ON pulse width: 30 μs
High-speed counter inputs 4 max. (2 per Pulse I/O Module)
Input method: Differential-phase (×4) pulses, pulse +
direction, up/down pulses, or increment pulse
Maximum response frequency: 50 kHz for differential
phases or 100 kHz for single phase
Counting mode: Linear mode or circular (ring) mode
Count value: 32 bits
Counter reset: Phase Z + software reset or software
reset
Control method: Target-value comparison or range
comparison
Gate function: Supported
Pulse Outputs Can be used as normal outputs, pulse outputs, or
PWM outputs.
(Functions of each output must be selected in the PLC
Setup.)
Output method: Sinking or sourcing transistor outputs
(The method is determined by Pulse I/O Module model.)
Normal outputs 12 max. (6 per Pulse I/O Module)
Pulse outputs 4 max. (2 per Pulse I/O Module)
Output method: CW/CCW or pulse + direction (The
method is determined by the I/O wiring and the
instructions used in the ladder program.)
Output frequency: 1 pps to 100 kpps (in increments of
1 pps)
Output Mode: Continuous mode (for speed control) or
independent mode (for position control)
Output pulses: Relative coordinates: 0000 0000 to
7FFF FFFF hex (0 to 2,147,483,647 pulses)
Absolute coordinates: 8000 0000 to 7FFF FFFF hex
(-2,147,483,648 to 2,147,483,647)
Acceleration/deceleration curves: Linear or S-curve
Origin search function: Supported
PWM outputs 4 max. (2 per Pulse I/O Module)
Output frequency: 0.1 to 6,553.5 Hz (in 0.1-Hz increments)
or 1 to 32,800 Hz (in 1-Hz increments)
Duty ratio: 0.0% to 100.0% (in 0.1% increments)

*1. The following times are added if EtherNet/IP data tag links are used.
CJ3M-CPU3[]: 100 μs + Number of transfer words × 0.78 μs
When the Pulse I/O Module is mounted, 10 μs × number of mounted units is added.
*2. A960 to A1471 and A10000 to A11535 cannot be accessed by CPU Bus Units, Special I/O Units, PTs, and Support Software that do not specifically support the CJ2/CJ3 CPU Units.
*3. Bits in the EM Area can be addressed either by bit or by word. These bits cannot be addressed by CPU Bus Units, Special I/O Units, PTs, and Support Software that do not specifically support the CJ3 CPU Units.
*4. Force-setting/resetting bits in the EM Area is possible either for banks that have been specified for automatic address allocation or for banks specified for the EM Area force-set/reset function.
*5. This data type cannot be used in Function blocks.
*6. This data type can be used only in Function blocks.
*7. The EtherNet/IP port is built into the CJ3M-CPU3[] only.
*8. “Packets per second” is the number of communications packets that can be processed per second.
*9. Large Forward Open (CIP optional specification) must be supported in order for 505 to 1,444 bytes to be used as the data size. Application is supported between CS/CJ-series PLCs. When connecting to devices from other manufacturers, make sure that the devices support the Large Forward Open specification.
*10. If the maximum number is exceeded, refreshing will require more than one CPU Unit cycle.
*11. When changing parameters, however, the EtherNet/IP port where the change is made will be restarted. In addition, a timeout will temporarily occur at the other node that was communicating with that port, and it will then recover automatically.
*12. The EtherNet/IP port supports an IGMP client, so unnecessary multicast packets are filtered by using an Ethernet switch that supports IGMP snooping.

Function Specifications

Functions Description
Cycle Time
Management
Minimum Cycle Time A minimum cycle time can be set.
(0.2 to 32,000 ms; Unit: 0.1 ms)
The minimum cycle time setting can be changed
in MONITOR mode
Cycle Time Monitoring The cycle time is monitored.
(10 to 40,000 ms; Unit: 10 ms)
Background Processing Instructions with long execution times can be
executed over multiple cycles to prevent fluctuations
in the cycle time.
Unit (I/O)
Management
Basic I/O
Units,
Special I/O
Units, and
CPU Bus
Units
I/O
Refreshing
Cyclic
Refreshing
Cyclic refreshing of Basic I/O Units, Special I/O Units,
and CPU Bus Units
Immediate
Refreshing
I/O refreshing by immediate refreshing instructions
Refreshing
by IORF
I/O refreshing by IORF instruction
Unit Recognition at
Startup
The number of units recognized when the power is
turned ON is displayed.
Basic I/O
Units
Input Response Time
Setting
The input response times can be set for Basic I/O
Units.
The response time can be increased to reduce the
effects of chattering and noise at input contacts.
The response time can be decreased to enable
detecting shorter input pulses.
Load OFF Function All of the outputs on Basic I/O Units can be turned
OFF when an error occurs in RUN or MONITOR
mode.
Basic I/O Unit Status
Monitoring
Alarm information can be read from Basic I/O Units
and the number of Units recognized can be read.
Special I/O
Units and
CPU Bus
Units
Reading/writing data
using instructions for
specific Units
Special instructions can be used to read/write
required data for specific Units at high speed.
Unit Restart Bits to
Restart Units
A Special I/O Unit or CPU Bus Unit can be
restarted.
Configuration
Management
Automatic I/O Allocation
at Startup
I/O words can be automatically allocated to the
Basic I/O Units that are connected in the PLC to
start operation automatically without registering
Units into I/O tables.
I/O Table Creation The current unit configuration can be registered in
I/O tables to prevent it from being changed, to
reserve words, and to set words.
Rack/Slot First Word
Settings
The first words allocated to a Units on the Racks
can be set.
Pulse I/O
Functions
(When
using
Pulse I/O
Module)
Pulse Input
Functions
Normal Inputs Input signals are read during I/O refreshing and
stored in I/O memory.
Interrupt Inputs An interrupt task can be started when an input
signal turns ON or turns OFF.
Quick-response Inputs Input signals that are shorter than the cycle time
are read and stored in I/O memory.
High-speed Counter
Inputs
High-speed pulse signals are counted. Interrupt
tasks can also be started.
Pulse Output
Functions
Normal Outputs The status of I/O memory is output during I/O
refreshing.
Pulse Outputs A pulse signal is output with the specified
frequency and number of pulses at a fixed duty
ratio (50%).
PWM Outputs A pulse signal is output at the specified duty ratio.
Origin Searches The origin point of the machine is determined
according to the specified origin search
parameters while actually outputting pulses and
using the origin and origin proximity input signals
as conditions.
(Pulse inputs and outputs are also used for this
function.)
Memory
Management
Holding I/O Memory when
Changing Operating Modes
The status of I/O memory can be held when the
operating mode is changed or power is turned ON.
The forced-set/reset status can be held when the
operating mode is changed or power is turned ON.
File Memory Files (such as program files, data files, and
symbol table files) can be stored in Memory Card,
EM File Memory, or Comment Memory.
Built-in Flash Memory The user program and Parameter Area can be
backed up to an internal flash memory when
they are transferred to the CPU Unit.
EM File Function Parts of the EM Area can be treated as file memory.
Storing Comments I/O comments can be stored as symbol table files
in a Memory Card, EM file memory, or comment
memory.
EM Configuration EM Area can be set as trace memory or EM file memory.
Battery-free I/O Memory
Backup Function
This function holds DM Area (D), EM Area (E),
Holding Area (H), Counter (C), and Auxiliary
Area (A) data without the need for a battery when
the power is interrupted.
Memory Cards Automatic File Transfer at Startup A program file and parameter files can be read
from a Memory Card when the power is turned
ON.
Program Replacement during
PLC Operation
User programs can be transferred from a Memory
Card to CPU Unit during operation.
Function for Reading and
Writing Data from a
Memory Card
Data in I/O memory in the CPU Unit can be written
to a Memory Card in CSV/TXT format. Data in
CSV/TXT format in the Memory Card can be read to
I/O memory in the CPU Unit.
Communications ---
Peripheral (USB) Port Bus for communications with various kinds of
Support Software running on a personal
computer.
Serial Port ---
Host Link (SYSWAY)
Communications
Host Link commands or FINS commands placed
between Host Link headers and terminators can
be sent from a host computer or PT to read/write
I/O memory, read/control the operating mode, and
perform other operations for PLC.
No-protocol
Communications
I/O instructions for communications ports (such
as TXD/RXD instructions) can be used for data
transfer with peripheral devices such as bar
code readers and printers.
NT Link
Communications
I/O memory in the PLC can be allocated and
directly linked to various PT functions, including
status control areas, status notification areas,
touch switches, lamps, memory tables, and
other objects.
Peripheral Bus Bus for communications with various kinds of
Support Software running on a personal
computer.
Serial Gateway This gateway enables receiving and automatically converting FINS to the CompoWay/F.
Serial PLC Links Data is exchanged between CPU Units using
serial ports without communications
programming. PTs set to the 1:N NT Link
protocol can be included in the network.
EtherNet/IP Port *1 100Base-TX/10Base-T
Protocols: TCP/IP, UDP, ARP, ICMP (ping only),
BOOTP, LLDP
Applications: FINS, CIP, SNTP,
DNS (Client), FTP (Server), Modbus (Server)
CIP
Commu-
nications
Service
Tag Data
Links
Programless cyclic data exchanges with the
devices on the EtherNet/IP network.
Message
Commu-
nications
Any CIP commands can be received from the
devices on the EtherNet/IP network.
FINS
Commu-
nications
Service
Message
Commu-
nications
Any FINS commands can be transferred with the
devices on the EtherNet/IP network.
Socket
service
Message
Commu-
nications
Any data can be sent and received to and from
general-purpose devices over Ethernet.
Modbus
Commu-
nications
Service
Message
Commu-
nications
Modbus commands can be sent and received to
and from Modbus clients and Modbus servers
on an EtherNet/IP network.
Interrupt Scheduled Interrupts A task is executed at a specified interval.
Resetting and
restarting with MSKS
When MSKS is executed, the internal timer is
restarted and the time to first interrupt is set to a
fixed value.
Reading present value
of internal timer with
MSKR
MSKR can be used to read the time that has
elapsed until the scheduled interrupt is started or
since the previous scheduled interrupt.
Power OFF Interrupts A task can be executed when CPU Unit's power
turns OFF.
I/O Interrupts A task can be executed when an input signal is
input to an Interrupt Input Unit.
External Interrupts A task can be executed when interrupts are
requested from a Special I/O Unit or a CPU Bus
Unit.
Input Interrupt Function of Pulse
I/O Module
A task is started for an interrupt input from a Pulse
I/O Module or for a high-speed counter input.
Input Interrupts Interrupt tasks are executed when the interrupt
input turns ON or turns OFF.
Direct Mode: An interrupt task is executed each time
an input signal changes.
Counter Mode: Changes in the input signal are
counted up or down and the interrupt task is
executed when the counter counts out.
(The maximum response frequency is 3 kHz.)
High-speed Counter
Interrupts
An interrupt task is executed when preset
comparison conditions for a high-speed counter
are met.
Target-value comparison:
The interrupt task is executed when the count
matches a specified value.
Range comparison:
The interrupt task is executed when the count enters
or leaves a specified range of values.
Clock Clock Function Clock data is stored in memory.
Accuracy (Accuracy depends on the temperature.)
Ambient temperature of 55°C: -3.5 to 0.5 min error
per month
Ambient temperature of 25°C: -1.5 to 1.5 min error
per month
Ambient temperature of 0°C: -3 to 1 min error
per month
Built-in Capacitor Backup Time At ambient temperature of 40°C: 10 days
Operation Start Time Storage The time when operating mode was last changed
to RUN mode or MONITOR mode is stored.
Operation Stop Time Storage The last time a fatal error occurred or the last time
the operating mode was changed to PROGRAM
mode is stored.
Startup Time Storage The time when the power was turned ON is stored.
Power Interruption Time Storage The time when the power is turned OFF is stored.
Total Power ON Time Calculation The total time that the PLC has been ON is stored
in increments of 10 hours.
Power ON Clock Data Storage A history of the times when the power was turned
ON is stored.
User Program Overwritten Time
Storage
The time that the user program was last overwritten
is stored.
Parameter Date Storage The time when the Parameter Area was overwritten
is stored.
Power Supply Management Memory Protection Holding Area data, DM Area data, EM Area data,
Counter Completion Flags, and counter present
values are held even when power is turned OFF.
CIO Area, Work Area, some Auxiliary Area data, and
Timer Completion Flags, timer present values,
index registers, and data registers can be protected
by turning ON the IOM Hold Bit in the Auxiliary Area,
and by also setting the IOM Hold Bit to “Hold” in
the PLC Setup.
Power OFF Detection Time Setting The detection time for power interruptions can be
set.
AC power supply: 10 to 25 ms (variable)
DC power supply: 2 to 5 ms (CJ1W-PD022) or 2
to 20 ms (CJ1W-PD025)
Power OFF Detection Delay Time The detection of power interruptions can be
delayed: 0 to 10 ms (Not supported by the
CJ1W-PD022.)
Number of Power Interruptions
Counter
The number of times power has been interrupted
is counted.
Function Blocks Standard programming can be encapsulated as
function blocks.
Languages in Function Block
Definitions
Ladder programming or structured text
Debugging Online Editing The program can be changed during operation
(in MONITOR or PROGRAM mode), except for
block programming areas.
Force-Set/Reset Specified bits can be set or reset.
A parameter can be set to enable force-setting/
resetting bits in EM Area banks.
Force-setting/resetting is enabled for the specified
bank and all the banks after it.
Differentiate Monitoring ON/OFF changes in specified bits can be monitored.
Data Tracing The specified I/O memory data can be stored in the
trace memory in the CPU Unit.
The triggers can be set.
Continuous Tracing The trace data can be uploaded during data tracing
using the CX-Programmer.
This enables continuously logging the data by
constantly uploading the trace data.
Automatically starting
tracing when operation
starts
Data tracing can be automatically started when
operation is started (i.e., when the operating mode
is changed from PROGRAM mode to MONITOR or
RUN mode).
Storing Location of Error when an
Error Occurs
The location and task number where execution
stopped for a program error is recorded.
Program Check The programs can be checked for items such as no
END instruction and FALS/FAL errors at startup.
Self-
diagnosis
and
Restoration
Error Log A function is provided to store predefined error
codes in CPU Unit, error information, and time at
which the error occurred.
CPU Error Detection CPU Unit WDT errors are detected.
User-defined Failure Diagnosis Errors can be generated for user-specified
conditions:
Non-fatal errors (FAL) and fatal errors (FALS).
Program section time diagnosis and program
section logic diagnosis are supported
(FPD instruction).
Load OFF Function This function turns OFF all outputs from Output
Units when an error occurs.
RUN Output The RUN output from the CJ1W-PA205R turns ON
while CPU Unit is in RUN mode or MONITOR mode.
Basic I/O Load Short-circuit Detection This function provides alarm information from Basic
I/O Units that have load short-circuit protection.
Failure Point Detection The time and logic of an instruction block can be
analyzes using the FPD instruction.
CPU Standby Detection This function indicates when the CPU Unit is on
standby because all Special I/O Units and CPU Bus
Units have not been recognized at the startup in
RUN or MONITOR mode.
Non-fatal Error
Detection
System FAL Error
Detection (User-
defined non-fatal error)
This function generates a non-fatal (FAL) error when
the user-defined conditions are met in program.
Duplicated Refreshing
Error Detection
This function detects an error when an immediate
refreshing Instruction in an interrupt task is
competing with I/O refreshing of a cyclic task.
Basic I/O Unit Error
Detection
This function detects the errors in Basic I/O Units.
Backup Memory
Error Detection
This function detects errors in the memory backup
of the user programs and parameter area (backup
memory).
PLC Setup Error Detection This function detects setting errors in the PLC Setup.
CPU Bus Unit Error
Detection
This function detects an error when there is an error
in data exchange between the CPU Unit and a CPU
Bus Unit.
Special I/O Unit Error
Detection
This function detects an error when there is an error
in data exchange between the CPU Unit and a
Special I/O Unit.
Tag Memory Error
Detection
This function detects errors in tag memory.
Battery Error Detection This function detects an error when a battery is not
connected to the CPU Unit or when the battery
voltage drops.
CPU Bus Unit Setting
Error Detection
This function detects an error when the model of a
CPU Bus Unit in the registered I/O tables does not
agree with the model that is actually mounted in the
PLC.
Special I/O Unit Setting
Error Detection
This function detects an error when the model of a
Special I/O Unit in the registered I/O tables does not
agree with the model of Unit that is actually mounted.
Fatal
Error
Detection
Memory Error Detection This function detects errors that occur in memory of
the CPU Unit.
I/O Bus Error Detection This function detects when an error occurs in data
transfers between the Units mounted in Rack slots
and the CPU Unit and detects when the End Cover
is not connected to the CPU Rack or an Expansion
Rack.
Unit/Rack Number
Duplication Error
This function detects an error when the same unit
number is set for two or more Units, the same word
is allocated to two or more Basic I/O Units, or the
same rack number is set for two or more Racks.
Too Many I/O Points
Error Detection
This function detects an error when the total number
of I/O points set in the I/O tables or the number of
Units per Rack exceeds the specified range.
I/O Setting Error
Detection
The registered I/O tables are used to detect errors
if the number of Units in the registered I/O tables
does not agree with the actual number of Units
that are connected or an Interrupt Unit has been
connected in the wrong position.
Program Error Detection This function detects errors in programs.
Instruction
Processing
Error
Detection
This function detects an error when the given data value is invalid when executing an instruction, or execution of instruction between tasks was attempted.
Indirect
DM/EM
BCD Error
Detection
This function detects an error when an indirect
DM/EM address in BCD mode is not BCD.
Illegal Area
Access
Error
Detection
This function detects an error when an attempt is
made to access an illegal area with an instruction
operand.
No END
Error
Detection
This function detects an error when there is no END
instruction at the end of the program.
Task Error
Detection
This function detects an error when there are no
tasks that can be executed in a cycle, there is no
program for a task, or the execution condition for an
interrupt task was met but there is no interrupt task
with the specified number.
Differen-
tiation
Overflow
Error
Detection
This function detects an error when too many
differentiated instructions are entered or deleted
during online editing (131,072 times or more).
Invalid
Instruction
Error
Detection
This function detects an error when an attempt is
made to execute an instruction that is not defined in
the system.
User
Program
Area
Overflow
Error
Detection
This function detects an error when instruction data
is stored after the last address in user program area.
Cycle Time Exceeded
Error Detection
This function monitors the cycle time (10 to
40,000 ms) and stops the operation when the set
value is exceeded.
System FALS Error
Detection (User-
defined Fatal Error)
This function generates a fatal (FALS) error when
the user-defined conditions are met in program.
Version Error Detection This function detects an error when a user program
includes a function that is not supported by the
current unit version.
Memory Card Transfer
Error Detection
This function detects an error when the automatic
file transfer from Memory Card fails at startup.
Maintenance Simple Backup Function This function collectively backs up the data in CPU
Unit (user programs, parameters, and I/O memory)
and internal backup data in the I/O Units.
Unsolicited Communications A function that allows the PLC to use Network
Communications Instruction to send required FINS
commands to a computer connected via a Host Link
Remote Programming and Monitoring Host Link communications can be used for remote
programming and remote monitoring through a
Controller Link, Ethernet, DeviceNet, or SYSMAC
LINK Network.
Communications across network layers can be
performed. Controller Link or Ethernet: 8 layers
DeviceNet or SYSMAC LINK: 3 layers
Automatic Online
Connection via
Network
Direct
Connection
This function enables automatically connecting to
the PLC online when the CX-Programmer is directly
connected by a serial connection (peripheral (USB)
port or serial port).
Via
Networks
This function enables connecting the
CX-Programmer online to a PLC that is connected
via an EtherNet/IP network.
Security Read Protection using Password This function protects reading and displaying programs and tasks using passwords.
Write protection: Set using the DIP switch.
Read protection: Set a password using the
CX-Programmer.
FINS Write Protection This function prohibits writing by using FINS
commands sent over the network.
Unit Name Function This function allows the users to give any names to
the Units. Names are verified at online connection
to prevent wrong connection
Hardware ID Using Lot Numbers This function sets operation protection by identifying
hardware using the user programs according to lot
numbers stored in the Auxiliary Area.
Operation Log Function Function for recording important operations and the
results of operations performed by online users
while they are online together with the date, IP
address of PC, and user name.
Extended FINS Write Access Log Function for retaining a log of requests to write to
the CPU Unit from external sources when the
source address is not the local node.
File Encryption Function Function for encrypting files handled by
CX-Programmer, backup tools, and file memory to
prevent unauthorized access by third parties.
Secure Communications Function *2 Function for ensuring the confidentiality and integrity
of the line used to access important data on the
CPU Unit from peripheral tools.
User authentication *2 Function for allowing only specified users to perform
online operation from peripheral tools to further
restrict online operation based on privileges set for
each user.
Port Open/Close Function *2 Function for allowing you to block or allow
communications to pass through the TCP/ UDP
ports allocated to individual communication
functions according to the configured setting.
IP Packet Filter *2 Function for selectively allowing packets received by
the EtherNet/IP port to pass through based on
preset conditions.

*1. Supported only by CJ3M-CPU[].
*2. This function can be used only with CJ3M-CPU3[].

Specifications for Pulse I/O Functions

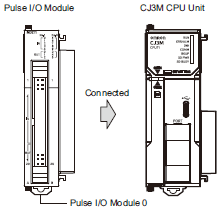
The following functions of CJ3M can be used by installing one or two Pulse I/O Modules. Each module has 10 high-speed inputs and 6 high-speed outputs.
• The inputs can be used as general-purpose inputs, interrupt inputs, quick-response inputs, high-speed counters, or origin search inputs.
• The outputs can be used as general-purpose outputs, pulse outputs, origin search outputs, or PWM outputs.

One Pulse I/O Module can be mounted

CJ3M-CPU3[] / -CPU1[] / CJ2M-MD21[] Specifications 8

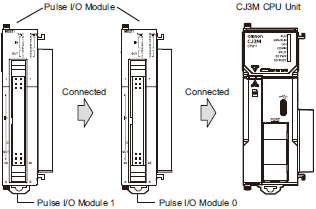
Two Pulse I/O Modules can be mounted

CJ3M-CPU3[] / -CPU1[] / CJ2M-MD21[] Specifications 9

Note: The Pulse I/O Module closest to the CPU Unit is Pulse I/O Module 0 and the other one is Pulse I/O Module 1.

Performance Specifications

Item Description
Pulse I/O Model of Pulse I/O Modules CJ2M-MD211 (Sinking-type)
CJ2M-MD212 (Sourcing-type)
External Interface 40-pin MIL connector
Pulse Inputs Can be used as normal inputs, interrupt inputs, quick-response inputs,
or high-speed counter inputs.
(Function of each input must be selected in the PLC Setup.)
Input method: Line-driver input or 24-VDC input (selected by wiring)
Normal Inputs 20 max. (10 per Pulse I/O Module)
Input constants: Set in the PLC Setup (0, 0.5, 1, 2, 4, 8, 16, or 32 ms).
Default: 8 ms
Interrupt Inputs and
Quick-response Inputs
8 max. (4 per Pulse I/O Module)
Input signal minimum ON pulse width: 30 μs
High-speed Counter Inputs 4 max. (2 per Pulse I/O Module)
Input method: Differential-phase (×4) pulses, pulse + direction,
up/down pulses, or increment pulse
Maximum response frequency: 50 kHz for differential phases or 100 kHz
for single phase
Counting mode: Linear mode or circular (ring) mode
Count value: 32 bits
Counter reset: Phase Z + software reset or software reset
Control method: Target-value comparison or range comparison
Gate function: Supported
Pulse Outputs Can be used as normal outputs, pulse outputs, or PWM outputs.
(Function of each output must be selected in the PLC Setup.)
Output method: Sinking or sourcing transistor outputs (The method is
determined by Pulse I/O Module model.)
Normal Outputs 12 max. (6 per Pulse I/O Module)
Pulse Outputs 4 max. (2 per Pulse I/O Module)
Output method: CW/CCW or pulse + direction (The method is
determined by the I/O wiring and the instructions used in the ladder
program.)
Output frequency: 1 pps to 100 kpps (in increments of 1 pps)
Output Mode: Continuous mode (for speed control) or independent
mode (for position control)
Output pulses: Relative coordinates: 0000 0000 to 7FFF FFFF hex
(0 to 2,147,483,647 pulses)
Absolute coordinates: 8000 0000 to 7FFF FFFF hex (-2,147,483,648
to 2,147,483,647)
Acceleration/deceleration curves: Linear or S-curve
Origin search function: Supported
PWM Outputs 4 max. (2 per Pulse I/O Module)
Output frequency: 0.1 to 6,553.5 Hz (in 0.1-Hz increments) or 1 to
32,800 Hz (in 1-Hz increments)
Duty ratio: 0.0% to 100.0% (in 0.1% increments)

Function Specifications

Functions Description
Pulse I/O
Functions
Pulse Input
Functions
Normal Inputs Input signals are read during I/O refreshing and stored in I/O memory.
Interrupt Inputs An interrupt task can be started when an input signal turns ON or
turns OFF.
Quick-
response
Inputs
Input signals that are shorter than the cycle time are read and stored
in I/O memory.
High-speed
Counter
Inputs
High-speed pulse signals are counted. Interrupt tasks can also be
started.
Pulse Output
Functions
Normal Outputs The status of I/O memory is output during I/O refreshing.
Pulse Outputs A pulse signal is output with the specified frequency and number of
pulses at a fixed duty ratio (50%).
PWM Outputs A pulse signal is output at the specified duty ratio.
Origin Searches The origin point of the machine is determined according to the
specified origin search parameters while actually outputting pulses
and using the origin and origin proximity input signals as conditions.
(Pulse inputs and outputs are also used for this function.)
Interrupt Input Interrupt Function A task is started for an interrupt input from a Pulse I/O Module or for a
high-speed counter input.
Input Interrupts Interrupt tasks are executed when the interrupt input turns ON or turns
OFF.
Direct Mode: An interrupt task is executed each time an input signal
changes.
Counter Mode: Changes in the input signal are counted up or down
and the interrupt task is executed when the counter counts out.
(The maximum response frequency is 3 kHz.)
High-speed Counter
Interrupts
An interrupt task is executed when preset comparison conditions for
a high-speed counter are met.
Target-value comparison: The interrupt task is executed when the
count matches a specified value. Range comparison: The interrupt
task is executed when the count enters or leaves a specified range
of values.

Specifications of Pulse Input Functions

Interrupt Inputs

Item Direct Mode Counter Mode
Number of interrupt inputs Max. 8 inputs
Allocated bit CIO 2960 and CIO 2962, bits 00 to 03
Interrupt detection method ON-to-OFF or OFF-to-ON transitions
Interrupt task numbers 140 to 147 (fixed)
Counting method --- Incrimenting or decrementing
(Set with the MSKS(690) instruction.)
Counting range --- 0001 to FFFF hex (16 bits)
(Set in A532 to A535 and A544 to A547.)
Response frequency --- Single-phase: 3 kHz × 8 inputs
Storage locations for PVs for
interrupt inputs in Counter Mode
--- A536 to A539 and A548 to A551

Quick-response inputs

Item Specifications
Number of Quick-response inputs Max. 8 inputs
Quick-response inputs Signals that are shorter than the cycle time are latched for one PLC cycle,
so they can be detected in the PLC program.
Minimum detectable pulse width is 30 μs.

High-speed Counter Inputs

Item Description
Number of High-speed
Counter Inputs
Max. 4 inputs
Pulse input method
(counting mode)
Incremental pulse
inputs
Differential phase
input (4×)
Up/down inputs Pulse + direction
inputs
Input signals Increment pulse Phase A Up pulse Pulse
--- Phase B Down pulse Direction
--- Phase Z Reset Reset
Frequency and number
of high-speed counters
100 kHz, 2 inputs
× 2 I/O Modules
50 kHz, 2 inputs
× 2 I/O Modules
100 kHz, 2 inputs
× 2 I/O Modules
100 kHz, 2 inputs
× 2 I/O Modules
Counting mode Linear mode or ring mode
Count value Linear mode: 8000 0000 to 7FFF FFFF hex
0000 0000 to FFFF FFFF hex (for increment pulse)
Ring mode: 0000 0000 to Max. ring value
High-speed counter PV
storage locations
High-speed counter 0: A271 (upper 4 digits) and A270 (lower 4 digits)
High-speed counter 1: A273 (upper 4 digits) and A272 (lower 4 digits)
High-speed counter 2: A317 (upper 4 digits) and A316 (lower 4 digits)
High-speed counter 3: A319 (upper 4 digits) and A318 (lower 4 digits)
Refreshed during overseeing processing. Use PRV(881) to read the most recent PVs.
Data format: 8 digit hexadecimal
• Linear mode: 8000 0000 to 7FFF FFFF hex
0000 0000 to FFFF FFFF hex (for increment pulse)
• Ring mode: 0000 0000 to Max. ring value
Control
method
Target value
comparison
Up to 48 target values and corresponding interrupt task numbers can be registered.
Range
Comparison
Up to 8 or up to 32 ranges can be registered, with a separate upper limit, lower limit,
and interrupt task number for each range.
Counter reset method • Phase-Z + Software reset
The counter is reset when the phase-Z input goes ON while the Reset Bit (A531.00 to
A531.03) is ON.
• Software reset
The counter is reset when the Reset Bit (A531.00 to A531.03) is turned ON.
Operation can be set to stop or continue the comparison operation when the high-speed
counter is reset.

Specifications of Pulse Output Functions

Position Control and Speed Control

Item Specifications
Number of Pulse Outputs Max. 4 outputs (Pulse Output 00 to 03)
Output mode Continuous mode (for speed control) or independent mode (for position control)
Positioning
(independent mode)
instructions
PULS (886) and SPED (885), PULS (886) and ACC (888), or PULS2
(887) instruction
Speed control
(continuous mode)
instructions
SPED (885) and ACC (888) instructions
Origin (origin search
and origin return)
instructions
ORG (889) instruction
Interrupt feeding instruction IFEED (892) instruction
Output frequency 1 pps to 100 kpps (1 pps units), two pulse outputs × 2 Pulse I/O Modules
Frequency acceleration
and deceleration rates
Set in increments of 1 pps for acceleration/deceleration rates from 1 to 65,535
pps (every 4 ms).
The acceleration and deceleration rates can be set independently only with
the PLS2 (887) instruction.
Changing SVs during
instruction execution
The target frequency, acceleration/deceleration rate, and target position can be
changed.
Pulse output method CW/CCW or pulse + direction
Number of output pulses Relative coordinates: 0000 0000 to 7FFF FFFF hex (Accelerating or decelerating
in either direction: 2,147,483,647)
Absolute coordinates: 8000 0000 to 7FFF FFFF hex (-2,147,483,648 to
2,147,483,647)
Relative/absolute
coordinate specifications
for pulse output PVs
Absolute coordinates are specified automatically when the origin location has
been defined by changing the pulse output PV with the INI (880) instruction or
performing an origin search with the ORG(889) instruction. Relative coordinates
must be used when the origin is undefined.
Relative pulse/absolute
pulse specifications
The pulse type can be specified with an operand in the PULS (886) or PLS2
(887) instruction.
Absolute pulses can be used when absolute coordinates are specified for the
pulse output PV, i.e. the origin location has been defined. Absolute pulse
cannot be used when relative coordinates are specified, i.e., when the origin
location is undefined. An instruction error will occur.
Pulse output PV's storage
location
The following Auxiliary Area words contain the pulse output PVs
Pulse output 0: A277 (leftmost 4 digits) and A276 (rightmost 4 digits)
Pulse output 1: A279 (leftmost 4 digits) and A278 (rightmost 4 digits)
Pulse output 2: A323 (leftmost 4 digits) and A322 (rightmost 4 digits)
Pulse output 3: A325 (leftmost 4 digits) and A324 (rightmost 4 digits)
The PVs are refreshed during regular I/O refreshing.

Variable-duty Pulse Outputs (PWM)

Item Specifications
Number of PWM Outputs Max. 4 outputs (PWM Output 00 to 03)
Duty ratio 0.0% to 100.0% in 0.1% increments
Frequency 0.1 Hz to 6,553.5 Hz (Set in 0.1-Hz increments.)
1 Hz to 32,800 Hz (Set in 1-Hz increments.)
Output mode Continuous Mode
Instruction PWM (891) instruction